MBSG
 CFC
 PSG
 LYON
 SEV
 OSA
 NED
 OMA
 NZ
 IND
 NAM
 IRE
 PAK
 SL
 SA
 AUS
 Barcelona1
 Real Madrid2
 Udinese0
 Milan2
 Real Sociedad2
 Levante1
 Lecce0
 Juventus2
 NZ-A317
 IND-A113 & 488/8 (119 ov)
 SYL280/2 (84 ov)
 KHU
 MYMS465/7d
 CHATT317/3 (98 ov)
 DHA521
 RAJ103/6 (26 ov)
 RAN402
 BAR434/8 (122 ov)
 SIKM30/1 (15 ov)
 NAGA187
 JHK
 DELHI262/5 (75 ov)
 ODSA168/7 (72 ov)
 SVCS
 BRODA185/5 (59 ov)
 J & K
 CHD298/1 (66 ov)
 HP
 CGR
 AP209/8 (65.4 ov)
 HYD
 PNJB223/5 (70 ov)
 LUL
 SPR
 MOW
 TOK
 BRB
 MIS
 MEX-W51 (12.5/20 ov, target 187)
 ARG-W186/7
 NGA148
 UGA147/9 (20 ov, target 149)
 GMB112/9
 LES109 (19.5/20 ov, target 113)
 MOZ110/7 (19/20 ov, target 110)
 ZMB109/9
 IND-W328/6
 ZIM-W207 (48.5/50 ov, target 329)
 ENG241
 Abha
 Al Faisaly
 Sassuolo
 Lazio
 AS Roma
 Cagliari
 Torino
 Como
 NEF
 ITT
 Sunderland0
 Leeds0
 Freiburg1
 Bayern3
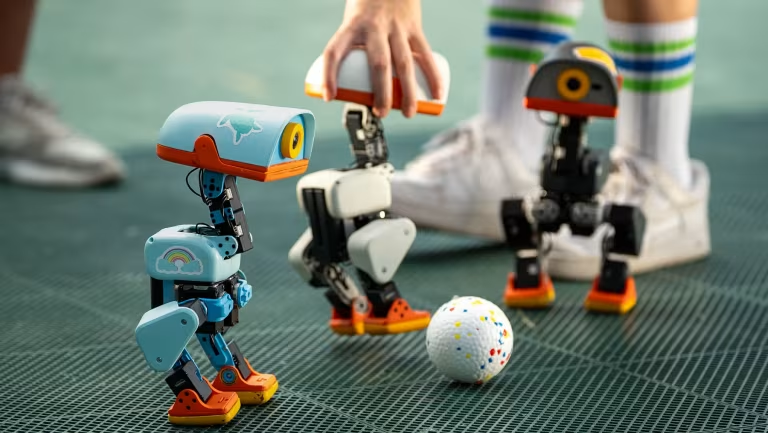
On October 21, 2026, NVIDIA took the stage at GTC Berlin and sent a ten-inch bipedal robot onto the floor. It walked on its own, showing that sim-to-real AI had moved beyond digital code and into physical hardware.
To understand the shift toward physical artificial intelligence, it helps to look at how virtual training translates to real-world machines. These five questions explain the mechanics, significance, and potential future accessibility of the recent Microduck demonstration.
What Exactly Is Microduck?
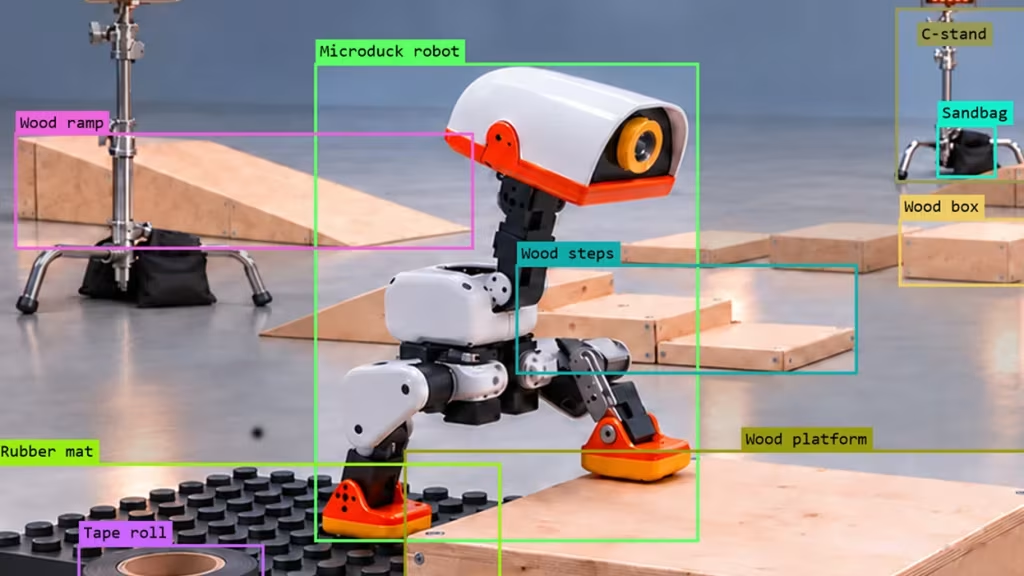
Microduck marks a tangible step toward connecting virtual software with physical hardware. This small bipedal robot tests whether complex motor skills developed in digital simulations can transfer directly to real-world mechanics. It stands about ten inches tall and weighs less than eight hundred grams, making it look modest beside human-sized humanoid prototypes.
Its value, though, comes from its purpose—not its size. A prominent machine learning community platform partnered with a dedicated robotics hardware manufacturer to develop the device. By keeping the hardware compact and relatively light, the team could focus on perfecting the neural networks beneath it. The robot’s ability to balance and take steps shows that basic locomotion algorithms can work without massive industrial actuators.
How Does Sim-to-Real AI Training Work?
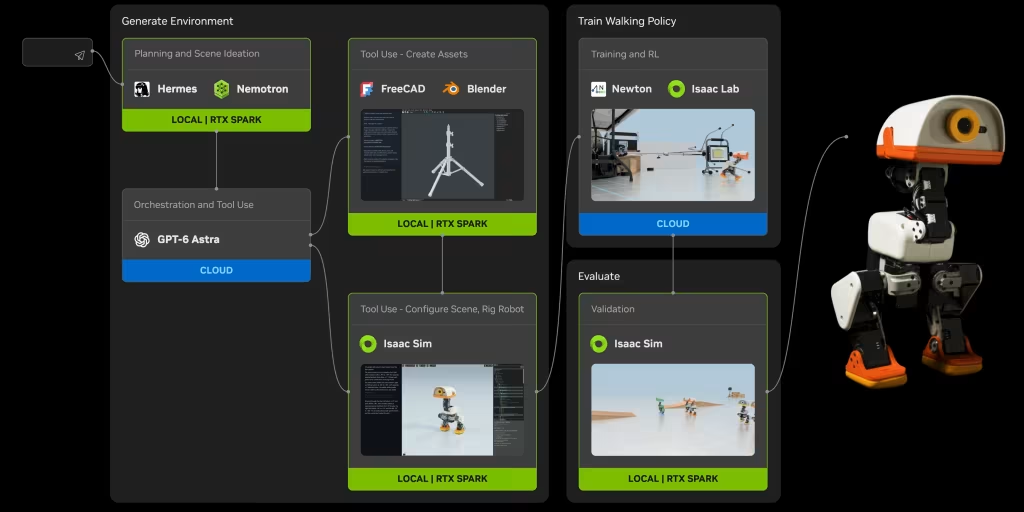
The demonstration’s main innovation uses a method called simulation-to-reality transfer. Researchers train the robot’s navigation and balance systems in a highly realistic digital twin before applying those controls to its physical frame.
Developers can run millions of trials, allowing the agent to stumble, recover, and adjust its center of gravity without risking costly hardware damage. Think of a toddler learning to walk through repeated attempts: the algorithm likewise gathers vast amounts of failure data, but safely inside a computer. When the neural network performs well enough in the virtual environment, engineers apply its learned policies to the physical motors. That means they don’t have to manually program every joint movement.
Why Did NVIDIA Choose This Specific Robot for GTC?
Bringing a miniature walker onto the main keynote stage gave abstract computing ideas a striking visual form. Microduck’s appearance turned theoretical discussions about artificial general intelligence into something concrete that attendees could see. The robot navigated the floor after three days of dense technical presentations on advanced semiconductor architecture. That timing made the demonstration a practical finale to the conference agenda, illustrating how AI can move from theory to physical hardware.
What Are the Physical Specifications of the Demonstration?
The prototype’s hardware favours efficiency over brute strength. The event ran from October 20 through 22, with the main keynote on the 21st. In practice, its knee-height profile suits controlled labs and precise indoor navigation, not heavy industrial work.
During the live presentation, the robot crossed the stage and stayed stable, demonstrating the effectiveness of its deployed control loop. Its mechanical design favors agility and rapid actuation cycles—both important when terrain shifts unexpectedly. These physical limits can actually help the research: they push software engineers to make their code as computationally efficient as possible.

Where Can Developers Access the Technology?
The release fits a wider industry push to make advanced robotic platforms more accessible. Software teams and independent researchers can use the shared frameworks to test their own reinforcement learning algorithms. After the initial showcase, developers distributed the underlying tools so outside groups could replicate the original training pipelines.
This open approach can speed up autonomous systems development in fields such as warehouse logistics and household assistance. By publishing training environments and physical specifications, the consortium encourages standardized benchmarks for embodied AI progress. That way, the next generation of physical robots can benefit from collaboration around the world. The move from virtual simulation to physical action marks a clear step forward for embodied AI.
FAQs
Will the Microduck AI robot replace human workers soon?
No. The current prototype is for research and education, not industrial labor. Its compact size and light build limit its ability to carry heavy objects or work in complex outdoor environments. The main goal is to validate reinforcement learning algorithms, not replace employees in factories or warehouses. Researchers still need to address major safety and scalability challenges before widespread commercial use is possible.
How does the simulation-to-reality method compare to traditional robot programming?
Traditional programming requires engineers to manually write precise mathematical equations for each joint movement and balance adjustment. That approach can struggle when a robot meets unexpected obstacles or uneven ground that no one programmed for. With simulation, the system learns through millions of randomized trials in a digital twin. The AI develops adaptive responses that transfer to physical hardware without constant human intervention.
Is the underlying technology available for independent academic research?
Yes. The participating organizations released the shared frameworks to support wider experimentation. Independent scholars and software teams can download the training environments and test their own neural network designs. This open-access strategy supports collaboration, helping advances in embodied intelligence spread across universities and startups worldwide.
Source: Hindustanherald
Was this article helpful?
Your feedback directly improves future articles on this site.